About Me
I am a Ph.D. student at the School of Computing and Data Science, The University of Hong Kong, supervised by Prof. Dong Xu and Prof. Peng Lu, working on robotics and embodied intelligence. My research focuses on data-efficient policy learning and world models for robotic manipulation, alongside 3D perception and adaptive gripper design. During my undergraduate studies at Zhejiang University, I received guidance from Prof. Jian Chen and Prof. Weifei Hu.
Research Interests
- Robotic Grasping and Manipulation: Adaptive grippers, dynamic object interaction, and contact-rich manipulation.
- 3D Perception for Robotics: 3D reconstruction, scene understanding, and world models for navigation and manipulation.
- Data-Efficient Robot Learning: Learning from reversed tasks, world-model-driven policies, and online adaptation with minimal human supervision.
News
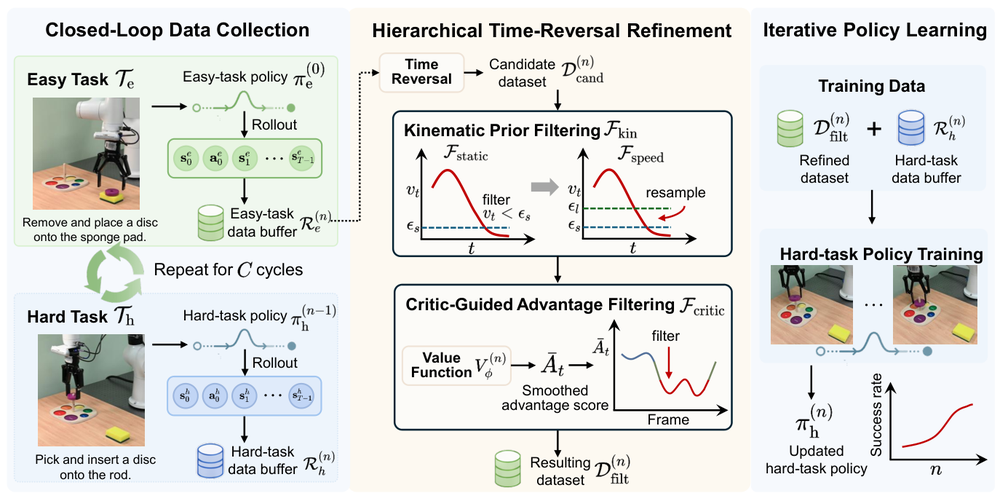
- [Sep. 2026] Our paper “Reverse to Advance” has been accepted to NeurIPS 2026!
- [Jul. 2026] “Reverse to Advance” is now on arXiv: learning hard manipulation tasks from reversed easy-task trajectories.
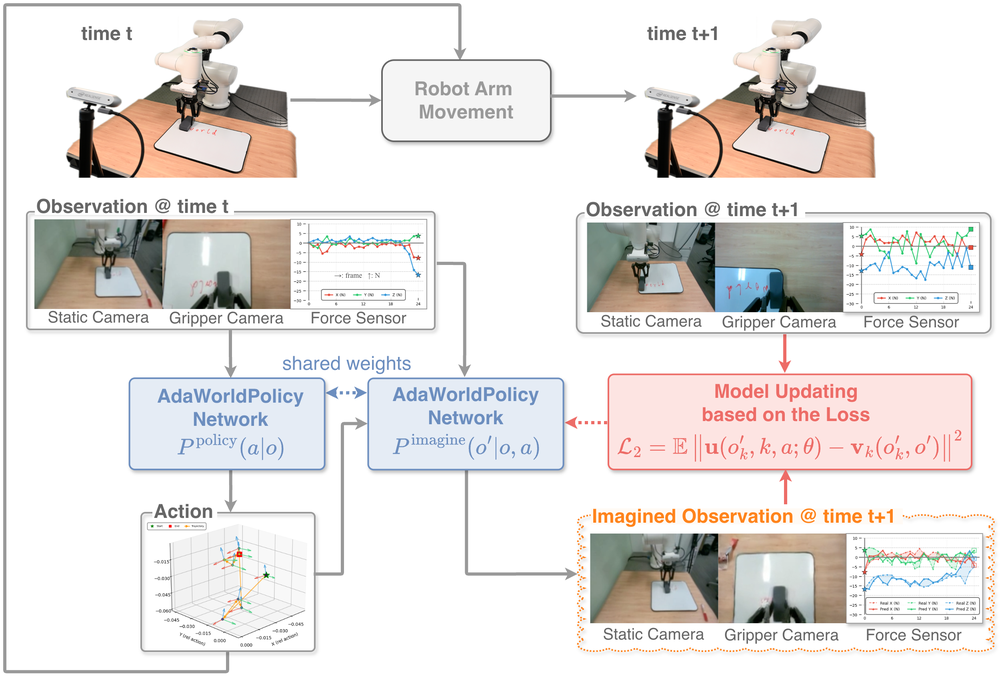
- [Feb. 2026] “AdaWorldPolicy” is now on arXiv. See the project page for world-model-driven manipulation with online adaptation.
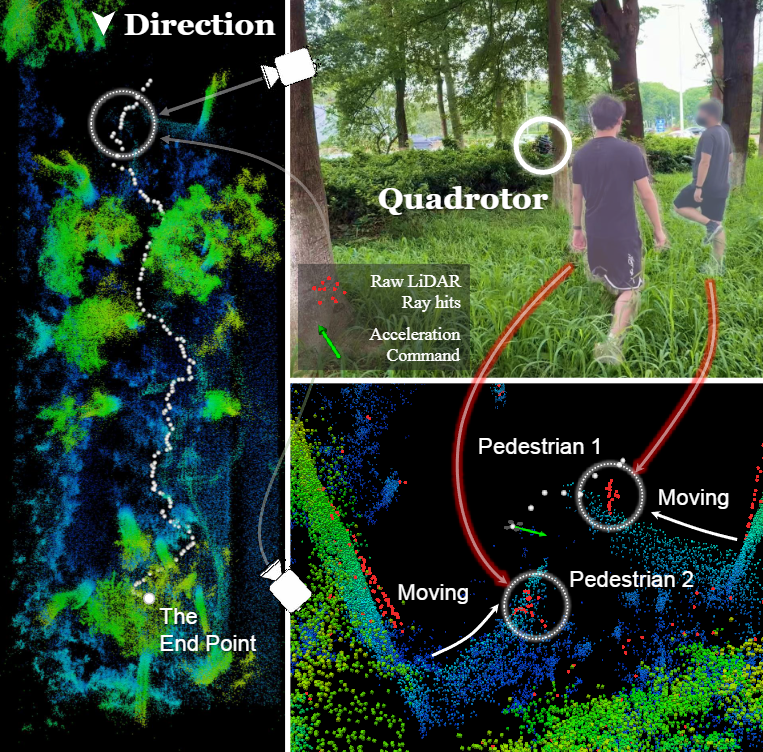
- [Nov. 2025] Our paper “Flow-Aided Flight Through Dynamic Clutters From Point to Motion” has been accepted to IEEE Robotics and Automation Letters (RA-L).
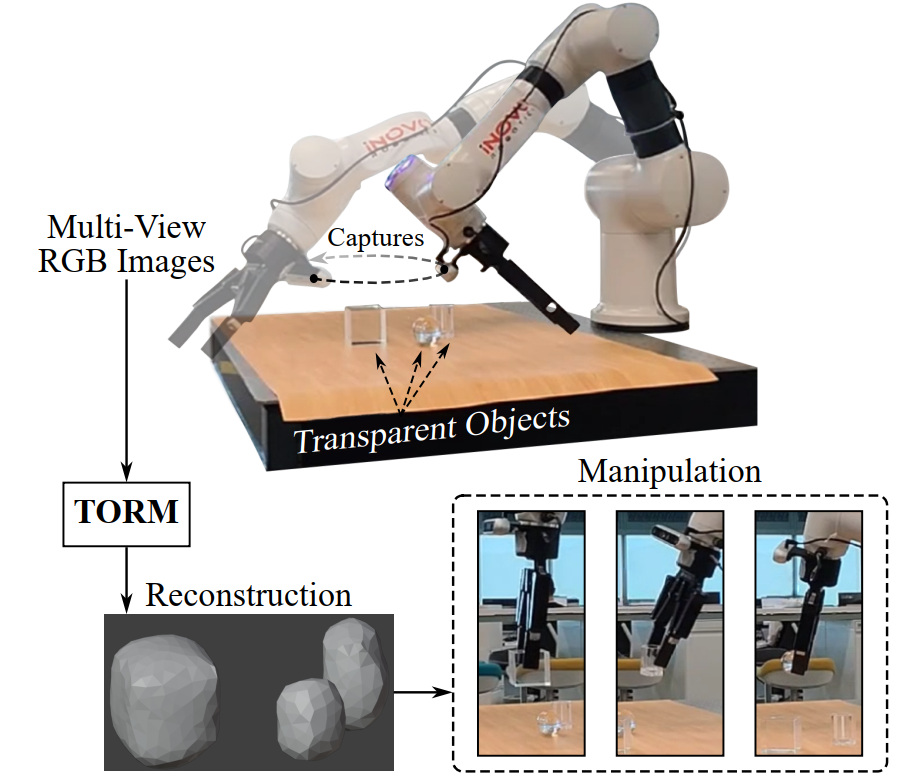
- [Nov. 2025] Our paper “TORM: Transparent Objects Reconstruction and Manipulation With Multi-View Segmentation” has been accepted to IEEE Robotics and Automation Letters (RA-L).
- [Oct. 2025] Our paper “Breaking the Static Assumption: A Dynamic-Aware LIO Framework via Spatio-Temporal Normal Analysis” has been accepted to IEEE Robotics and Automation Letters (RA-L).
- [Oct. 2025] Our paper “Lasso Gripper: A String Shooting-Retracting Mechanism for Shape-Adaptive Grasping” has been accepted to ROBIO 2025.
- [Dec. 2022] My patent “Wire-controlled flexible manipulator” (CN218110822U) has been granted.
Publications & Patents
Latest work first. See Google Scholar for citations.
-
NeurIPS 2026
Qiyuan Qiao, Ge Yuan, Can Wang, Dong Xu
Advances in Neural Information Processing Systems (NeurIPS), 2026 Accepted
-
arXiv 2026
Ge Yuan, Qiyuan Qiao, Jing Zhang, Dong Xu
arXiv preprint arXiv:2602.20057, 2026
-
RA-L
Bowen Xu, Zexuan Yan, Minghao Lu, Xiyu Fan, Yi Luo, Youshen Lin, Zhiqiang Chen, Yeke Chen, Qiyuan Qiao, Peng Lu
IEEE Robotics and Automation Letters
-
RA-L
Qiyuan Qiao, Fuling Lin, Huibin Zhao, Bowen Xu, Zhiqiang Chen, Dong Xu, Peng Lu
IEEE Robotics and Automation Letters
-
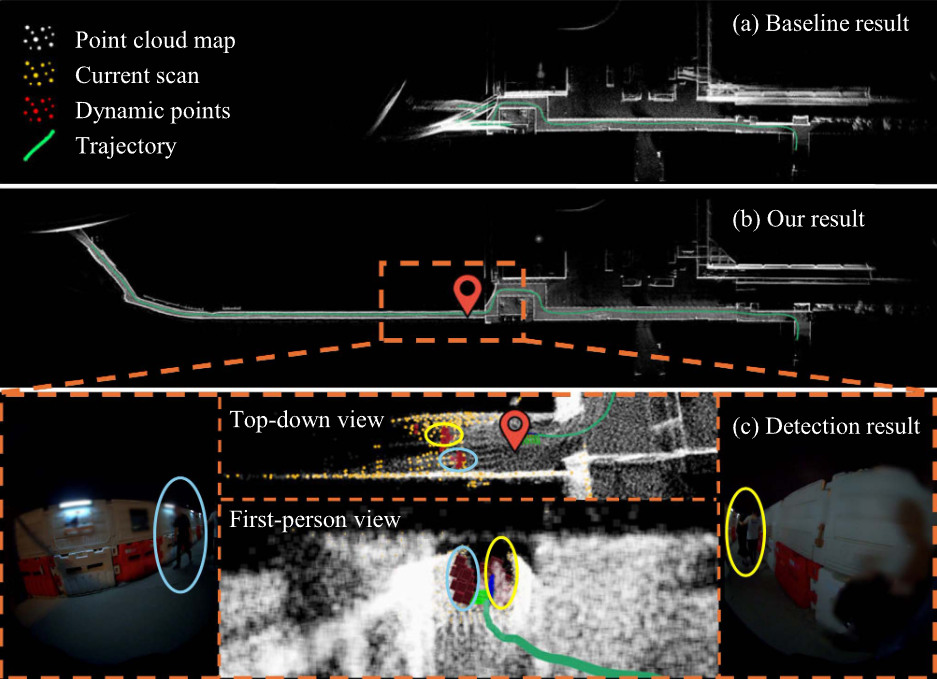
RA-L
Zhiqiang Chen, Cedric Le Gentil, Fuling Lin, Minghao Lu, Qiyuan Qiao, Bowen Xu, Yuhua Qi, Peng Lu
IEEE Robotics and Automation Letters
-
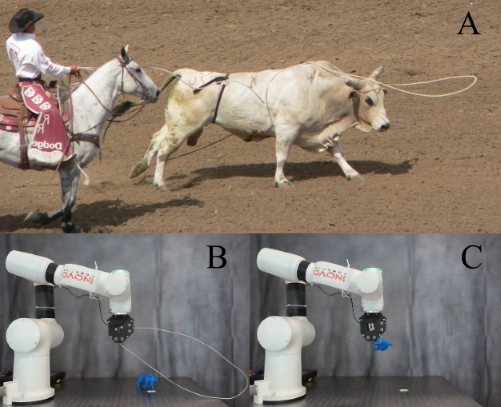
ROBIO
Qiyuan Qiao, Yu Wang, Xiyu Fan, Peng Lu
IEEE International Conference on Robotics and Biomimetics (ROBIO), 2025.
-
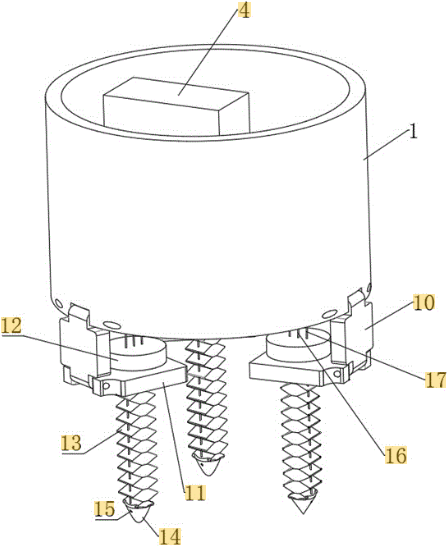
Patent
Qiyuan Qiao
Chinese Utility Model Patent CN218110822U
Education
- Ph.D. in Computer Science (2025–present), School of Computing and Data Science, The University of Hong Kong
- M.Phil. in Mechanical Engineering (2023–2025), The University of Hong Kong
- M.Sc. in Mechanical Engineering (2022–2023), The University of Hong Kong
- B.Eng. in Mechatronics Engineering (2018–2022), Zhejiang University
Services
Reviewer
- ICRA, IROS, RA-L, npj Artificial Intelligence
Teaching Assistant
- CCST9050 Robot: Flesh, Machines, Intelligence, The University of Hong Kong
- COMP3278 Introduction to database management systems, The University of Hong Kong
Powered by Jekyll and Minimal Light theme.
